MACHINE APPLICATION IN TEXTILE ART CREATION THROUGH AI ASSET CALCULATION AND PARALLEL KINEMATIC EXECUTION
DOI:
https://doi.org/10.71146/kjmr1032Keywords:
AI textile design, Kinematic detection, industrial designAbstract
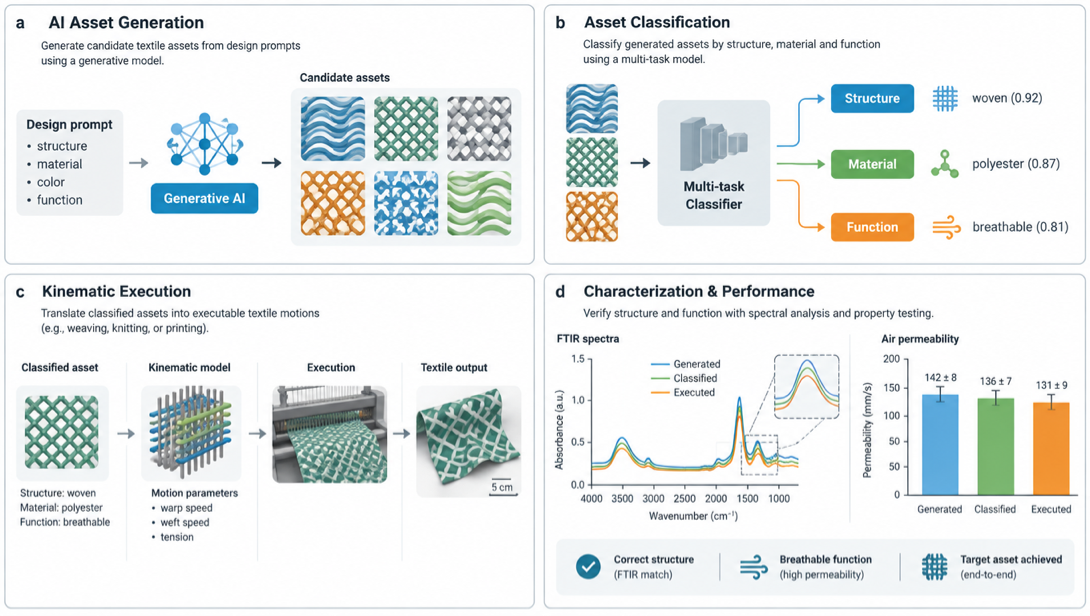
The intersection of artificial intelligence and physical manufacturing presents novel opportunities for textile art creation. This paper introduces a comprehensive framework that integrates AI-driven asset calculation with advanced machine application to automate and enhance the production of intricate textile designs. By employing generative algorithms and structured support vector machines, we calculate and classify high-fidelity digital textile assets. These assets are subsequently realized using high-speed parallel kinematic machines (PKMs), leveraging their superior structural rigidity and dynamic capacities. Ultimately, this approach bridges the gap between digital generative art and physical textile machining, offering a scalable solution for modern industrial design and custom fabrication.
Downloads
References
Perot, Cameron (2023). Quantum Boltzmann Machines: Applications in Quantitative Finance. https://arxiv.org/pdf/2301.13295v1
Liang, Rongmei, Liu, Zizheng, Wu, Xiaofei, & Tu, Jingwen (2025). Parallel Algorithms for Structured Sparse Support Vector Machines: Application in Music Genre Classification. https://arxiv.org/pdf/2512.07463v2
Guillen-Rondon, Pablo, Robinson, Melvin D., Torres, Carlos, & Pereya, Eduardo (2018). Support Vector Machine Application for Multiphase Flow Pattern Prediction. https://arxiv.org/pdf/1806.05054v1
Chablat, Damien, & Wenger, Philippe (2007). Architecture Optimization of a 3-DOF Translational Parallel Mechanism for Machining Applications, the Orthoglide. IEEE Transactions on Robotics and Automation 19, 3 (2003) 403-410. https://arxiv.org/pdf/0708.3381v1
Chablat, Damien, & Wenger, Philippe (2007). A New Concept of Modular Parallel Mechanism for Machining Applications. Proceeding IEEE International Conference on Robotics and Automation (2003) 1-6. https://arxiv.org/pdf/0705.1399v1
Wenger, Philippe, Gosselin, Clément, & Chablat, Damien (2007). A Comparative Study of Parallel Kinematic Architectures for Machining Applications. Dans 2nd Workshop on Computational Kinematics - WCK, Séoul : Corée, République de (05/2001). https://arxiv.org/pdf/0707.3665v1
Wenger, Philippe, & Chablat, Damien (2007). Design of a Three-Axis Isotropic Parallel Manipulator for Machining Applications: The Orthoglide. Workshop on Fundamental Issues and Future Research Directions for Parallel Mechanisms and Manipulators (2002) 1-9. https://arxiv.org/pdf/0705.1282v1
Chablat, Damien, & Wenger, Philippe (2007). A New Three-DOF Parallel Mechanism: Milling Machine Applications. The 2nd Chemnitz Parallel Kinematics Seminar (2000) 1-9. https://arxiv.org/pdf/0705.0982v1
Majou, Félix, Wenger, Philippe, & Chablat, Damien (2007). A Novel method for the design of 2-DOF Parallel mechanisms for machining applications. 8th International Symposium on Advances in Robot Kinematics (2002) 1-11. https://arxiv.org/pdf/0705.1280v1
Chablat, Damien, Wenger, Philippe, & Majou, Félix (2007). The Optimal Design of Three Degree-of-Freedom Parallel Mechanisms for Machining Applications. The 11Th International Conference on Advanced Robotics (2003) 1-6. https://arxiv.org/pdf/0705.1343v1
Downloads
Published
License
Copyright (c) 2026 Saba Mohauddin, Tehreem Ramzan, Mehak Iftikhar, Laraib Manzoor, Dr Anum Ali (Author)

This work is licensed under a Creative Commons Attribution 4.0 International License.
How to Cite